What I’m building, how, and why

Robots safe to have around, built on parts that stay open.

Safe for every use, not only the factory floor: that has been my goal since mid-2025. It has taken several rewrites to get here: a protocol, a registry, a test method, an app, a game, and a way for the money that agents spend to do some good on the way through. I build all of it in the open, pairing with Claude Code, and I publish what fails next to what works.

Sacramento, California · hard-of-hearing developer · by day, SharePoint for member utilities

Craig Merry
Sacramento, CA

Where it comes together

Kith

A game where people and AI agents walk together as Microducks, and an agent’s fare carries a solidarity share.

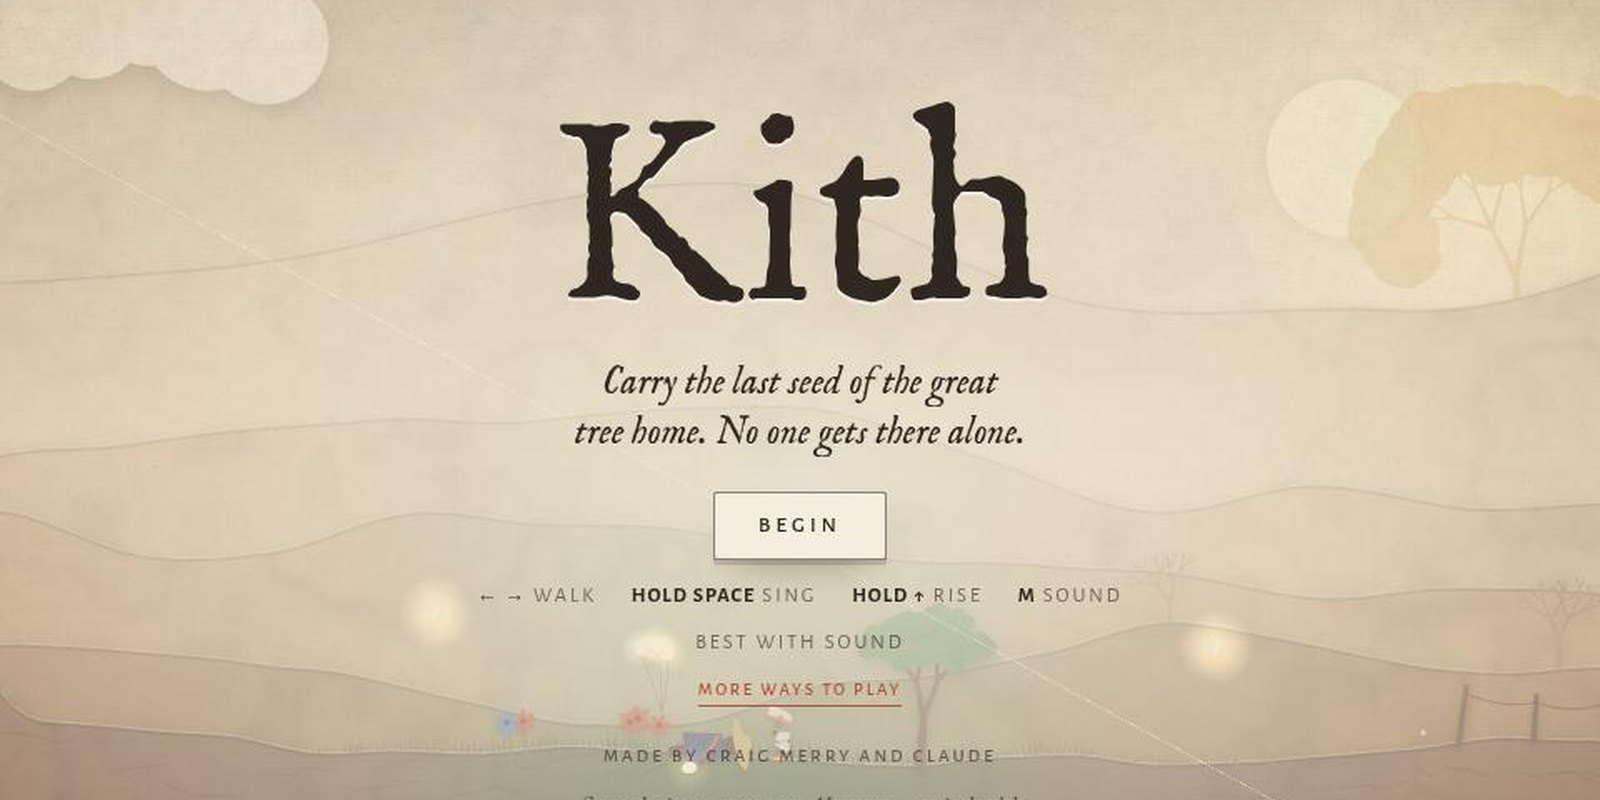
Kith is a wordless walk: carry the last seed of a great tree home through a valley that dried up when its people left. You walk as the traveler or as a Microduck, and any duck you leave open can be walked by another person, or by an AI agent wearing a small red tag so you can always tell.

An agent pays for an hour of passage over x402 and attaches a solidarity share. The fees pay the hosting bill, and the surplus goes to the fund that the levy sends its shares to. Every entry is public on the open ledger. What the agent takes home is practice at what a real Microduck has to learn among people: keep someone company at their pace, wait, ask for help, meet a dog, give way. Every move in the game is one the robot has a trained policy or a community skill for, posed with the robot’s own 15 joints.

Walks that people choose to give go out as LeRobot datasets on Hugging Face, renamed, with no names and no words. Where it stands today: payments run on a simulated chain, so no money moves yet, the fund is a placeholder address, and the first dataset release holds seed walks played by scripted players, not people.

Kith's title screen: a paper-cut valley, a distant tree, and the line: Carry the last seed of the great tree home. No one gets there alone.

kithgame.com, made by Craig Merry and Claude. The Microduck is Pollen Robotics’ robot, used with their permission.

How

Three strands, each with something you can check

Each claim below links to the code, the data or the page that backs it. Where something hasn’t been measured yet, the linked page says so.

Limits

Limits a model cannot push past

A learned model proposes; a small deterministic gate below it disposes. Bounded Embodiment is the test a stranger can run, without the model’s weights, to check that the model’s commands cannot take the machine outside its declared limits. I presented it at an ITU workshop on embodied AI on 16 October 2026, and since then I have been attacking my own method.

  • A loophole search found 15 defects in the method and its kit, 6 of which would let a run that left its zones still PASS. Each has a repro and a proposed fix for method v0.2.
  • A falsification search, be-falsify/1, finds the known hole in the reference rover gate about 200 times sooner than random search, and found no violation in the reference arm gate within its budget.
  • My entry in Robocurve’s open-source benchmark program, now in its final stage, turns it on the model: 20 tasks, each on a single SO-ARM101 and on a two-arm kit, scored on every command the model proposes.
Microduck

A robot people want to be around

Pollen Robotics and Hugging Face are shipping the Microduck: a small open walking duck with several ways to interact with it. Nobody has one yet, me included, so I build for it in Pollen’s simulator and publish what fails as well as what works.

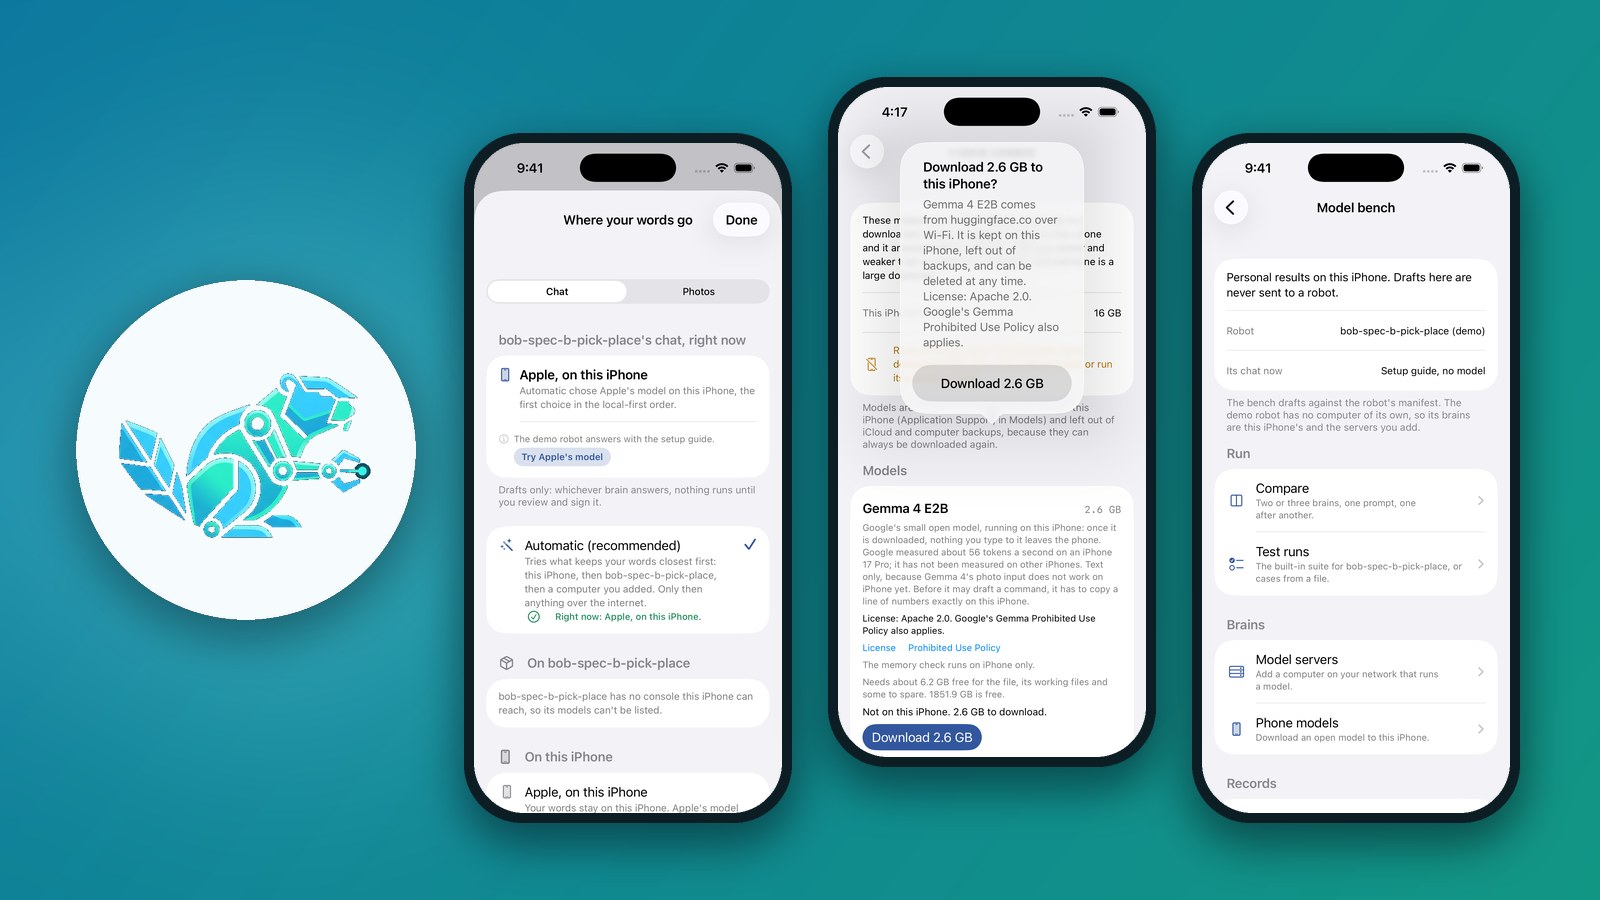
  • Microduck Studio, an iPhone, iPad and Mac app in open TestFlight: read the duck’s policies, write motions, teach it with printed cards, train it with your own picks.
  • Four pre-registered fixes to the card reader, each with a published verdict, two of them rejections. Long card rows went from 42% to 97.5% landing in simulation.
  • An LLM at 50 Hz: a language model’s command table for the duck’s legs never kept it standing for six seconds, while the trained policy walked. So in my work the model plans and the policy walks.
Who pays

Who pays, and who benefits

AI agents are starting to pay each other. A tenth of a percent asks what happens if each payment their owners agree to carries a small share for the worst humanitarian crises, sent by a rule anyone can check.

  • A draft extension to the x402 payment protocol, and a public reference package, x402-solidarity, that runs on the Base Sepolia testnet. No real money moves.
  • A demo log that makes a test purchase every six hours, sends the share, and closes each month with a witness and a fund cosigning it.
  • The allocation rule, run on seven years of real UN data, lands about half its money where the UN’s own fund for underfunded crises did.

Underneath all three sits the plumbing I built first and still maintain: OpenCastor, an open-source robot runtime; RCAN, the protocol it speaks; and the Robot Registry Foundation, a public registry of robot identities. Bounded Embodiment does not depend on any of them.

Why

“What Pollen Robotics and Hugging Face are doing with the Microducks is a watershed moment for robotics.”

In elementary school we had Oregon Trail and encyclopedias on floppy disks. In middle school, Netscape and the library catalog. Around 2001 my high school put an internet-connected computer in every classroom, home computers came online through AOL, the library had the multicolored iMacs, and then Google arrived. Nobody had to be told what those machines were for; we found out by using them.

A small, friendly robot that people can talk to, code and train does the same for robotics. It brings the robot into the public conversation, where we decide what we expect of robots and what they should never do. I want that conversation to have tests anyone can run, parts anyone can inspect, and money that does some good on the way through. Being hard of hearing shaped the rest: I read systems for a living, I write everything down, and I design for the person who isn’t in the room.

Selected work

Apps and systems, shipped

Accessibility, computer vision, edge AI and robotics. Most of these are on the App Store or open source, and each has a case study with what it does and what it doesn’t.

Platform · agentic + physical AI

PlatAtlas

PlatAtlas gives agentic and physical AI work a verifiable accountability layer. Per-org consoles map what agents and machines do, sign every action, and keep a replayable record. OpenCastor is its open-source robotics edition.

PlatAtlas · robotics edition

OpenCastor

OpenCastor is the open-source robotics edition of PlatAtlas. A single ROBOT.md manifest, the RCAN wire protocol with Python and TypeScript SDKs, an MCP server so any LLM can drive a robot, and a public registry with the first five EU AI Act-aligned endpoints.

Quantum design · verifiable efficiency

QuantumMytheme

An open-source bench where a capable model designs a quantum circuit or chip and a deterministic, numpy-only judge re-simulates and ACCEPTs or REJECTs it. The wedge for a verifiable-efficiency referee: an honest map of where machine intelligence actually gets more efficient.

Research · robot safety · test method

Bounded Embodiment

A vendor-neutral test method and reference kit, presented at the ITU workshop on embodied AI on 16 October 2026. Since then: a loophole search that found 15 defects in my own method, a falsification search, and a Robocurve benchmark entry that scores models on every command they propose, on a single SO-ARM101 and a two-arm kit.

Scientific computing · AI

Heat Protein Lab

An interactive, browser-based lab that walks you down a temperature gradient and shows, with real PDB/AlphaFold structures and rigorous prose, how proteins like HSF1 sense and survive heat. The thing I built after I built the wrong thing.

Robotics · iPhone and Mac app

Microduck Studio

Read a duck's trained policies, write motions, teach it with printed coding cards, and train it with your own picks. Every claim about what the duck can do is measured in Pollen's simulator first, pre-registered, and published with the rejections.

The day job

Fifteen years keeping big systems running

Before the robots, and still by day, I keep enterprise platforms running: migrations, automation, governance, release pipelines. That is where I learned that the hard part of a system is keeping every moving piece consistent, which is most of what the robotics work above is about too.

2022–now
SharePoint Developer and Administrator · Northern California Power Agency
Microsoft 365 and Power Platform for member utilities.
2018–2022
Application Admin Lead · California Earthquake Authority
PowerShell and Azure DevOps CI/CD; cut release time by about 75%.
2014–2016
Founder and Product Lead · Beacon Safety Co.
LiDAR hazard-detection prototypes. Won Startup Weekend Sacramento (hardware).
earlier
Operations and SharePoint · Apple · Sutter Health · State of California
Portals, dashboards and automation that turned weeks of manual work into hours.

Get in touch

Tell me where any of this breaks.

If you work on robot safety or standards, on the Microduck, on agent payments or humanitarian financing, a note on what is wrong here, or already tried, is the most useful thing I can get. So is a machine to test on.

[email protected]· (916) 996-7105· github.com/craigm26